- Client
- Private client
- Source
- Robot model supplied by the client
- Made for
- Animation
- Services
- Character rigging
The brief
The client sent a finished hard-surface model of a four-legged robot and needed it rigged so it could be posed and animated.
What we did
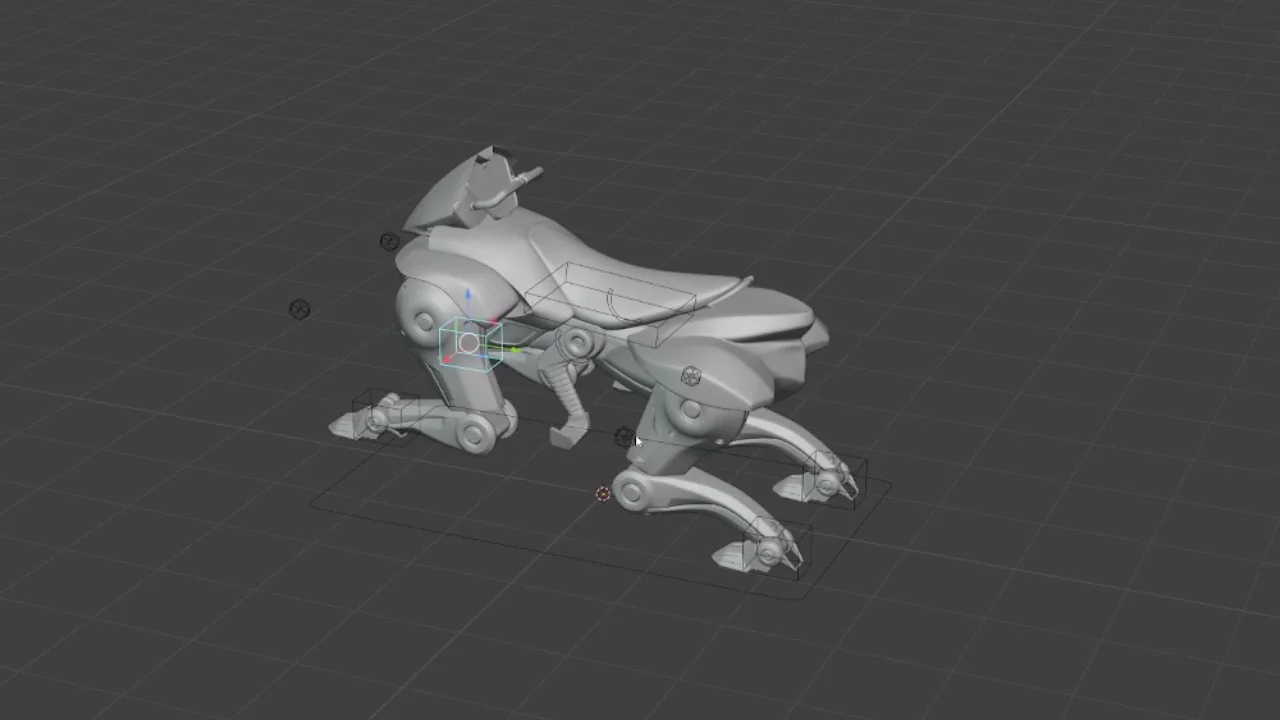
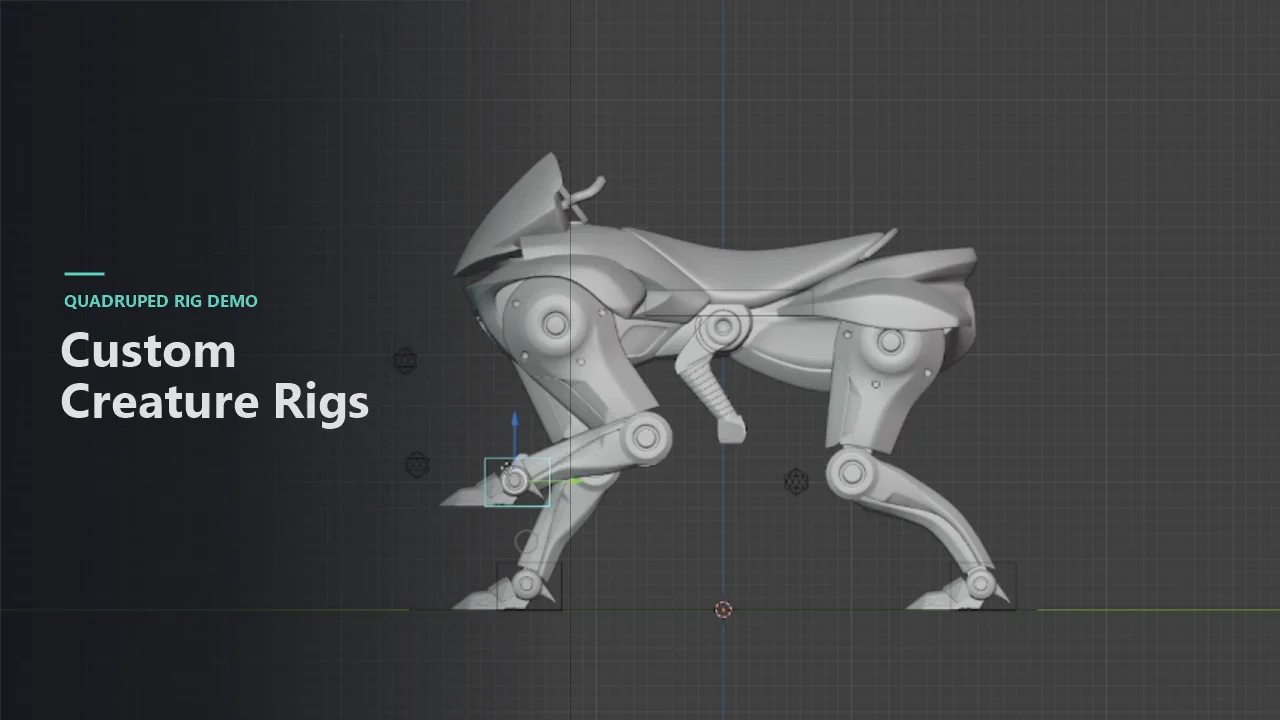
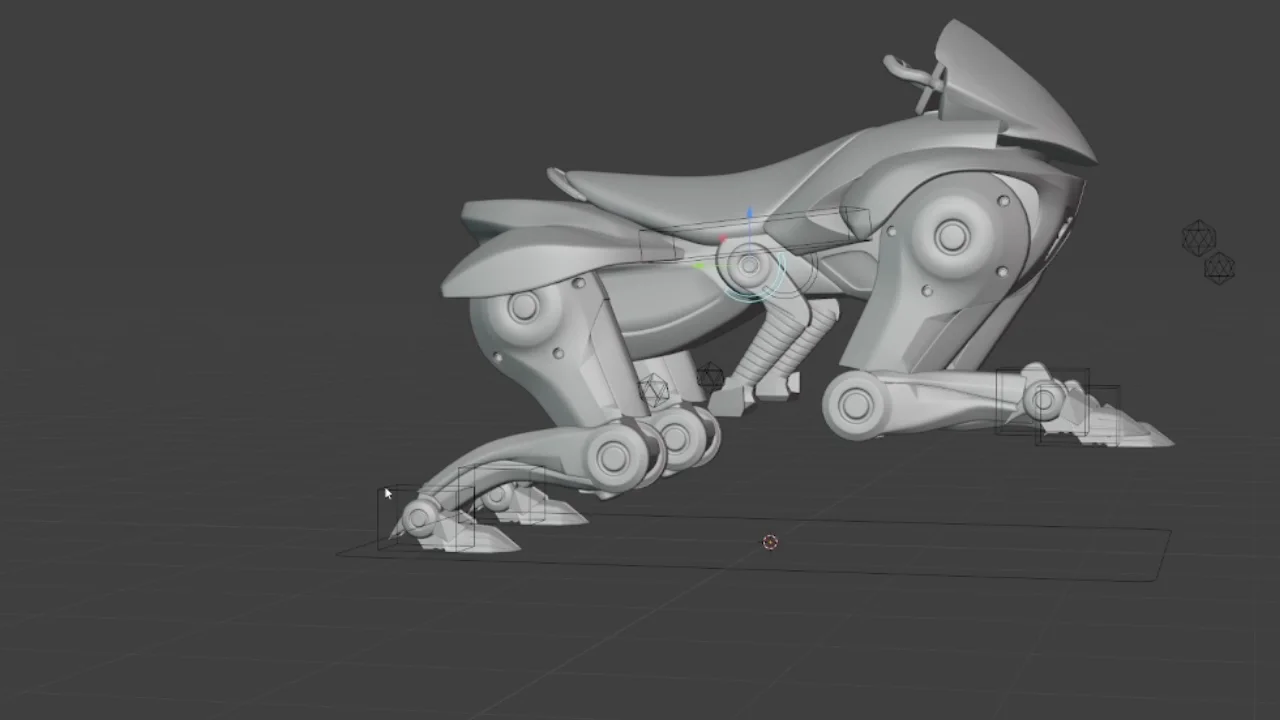
Each leg got its own joint chain, placed on the model's mechanical pivots so the plates and joints turn where they are built to turn. Controls at the feet keep them planted while the body moves. The rig was then put through standing, crouching and low prone poses in the viewport to check that the parts stay together.
Process
From the first idea to the final file
Stage 01
Rig and controls
Leg chains and foot controls on the client's model
Joints placed on the robot's own pivots for all four legs, with a control at each foot. The model stays as the client made it; the rig only moves it.
Stage 02
Rig test
Posed and moved through its range
A viewport recording of the rig in use: the robot stands, crouches and drops low while the legs fold and the feet stay planted.
Before and after